#include <init.hpp>
Definition at line 20 of file init.hpp.
◆ ~SubspaceDiagonalizer()
| virtual q3::SubspaceDiagonalizer::~SubspaceDiagonalizer |
( |
| ) |
|
|
virtualdefault |
◆ is_collective()
| virtual bool q3::SubspaceDiagonalizer::is_collective |
( |
| ) |
const |
|
inlinevirtual |
Whether solve() is a collective operation over the process group.
Collective solvers (ScaLAPACK) require EVERY rank of the group to call solve() — gating the call on one rank deadlocks the group — and return redundant results on all ranks, so no post-solve broadcast is needed. Non-collective solvers (serial LAPACK) may be called on the group root only, with results broadcast afterwards.
Definition at line 54 of file init.hpp.
◆ name()
| virtual std::string q3::SubspaceDiagonalizer::name |
( |
| ) |
const |
|
pure virtual |
◆ solve()
| virtual int q3::SubspaceDiagonalizer::solve |
( |
int |
basis_size, |
|
|
Complex * |
hamiltonian_matrix, |
|
|
Complex * |
overlap_matrix, |
|
|
Real * |
eigenvalues, |
|
|
Complex * |
eigenvector_matrix, |
|
|
bool |
is_gamma_only = false |
|
) |
| |
|
pure virtual |
Solve the generalized eigenvalue problem: H * C = S * C * E
- Parameters
-
| basis_size | Dimension of the subspace (matrix size). |
| hamiltonian_matrix | Projected Hamiltonian (destroyed/overwritten). May be the same buffer as eigenvector_matrix: every implementation reads it whole before it writes any eigenvector, which is what lets the caller keep one copy of H rather than two. |
| overlap_matrix | Projected overlap (destroyed/overwritten). |
| eigenvalues | Output eigenvalues (size basis_size). |
| eigenvector_matrix | Output eigenvectors (basis_size x basis_size). |
- Returns
- 0 on success, non-zero on failure.
Implemented in q3::SerialSubspaceDiagonalizer.
The documentation for this class was generated from the following file:
- src/layer_4_computation/diagonalizer/planewave/subspace/init.hpp
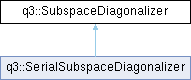
 Inheritance diagram for q3::SubspaceDiagonalizer:
 1.9.8